Welcome to RoBorregos @Home
Welcome to the @Home competition documentation of RoBorregos, Robotics Representative Team of Tecnológico de Monterrey. This documentation serves as a guide for our project, which focuses on researching and developing a multiproposal modular service robot for the RoboCup@Home competition. Our goal is to create a comprehensive software architecture that enables robots to perform various tasks that humans typically handle on a daily basis and adapting this software architecture in affordable hardware.

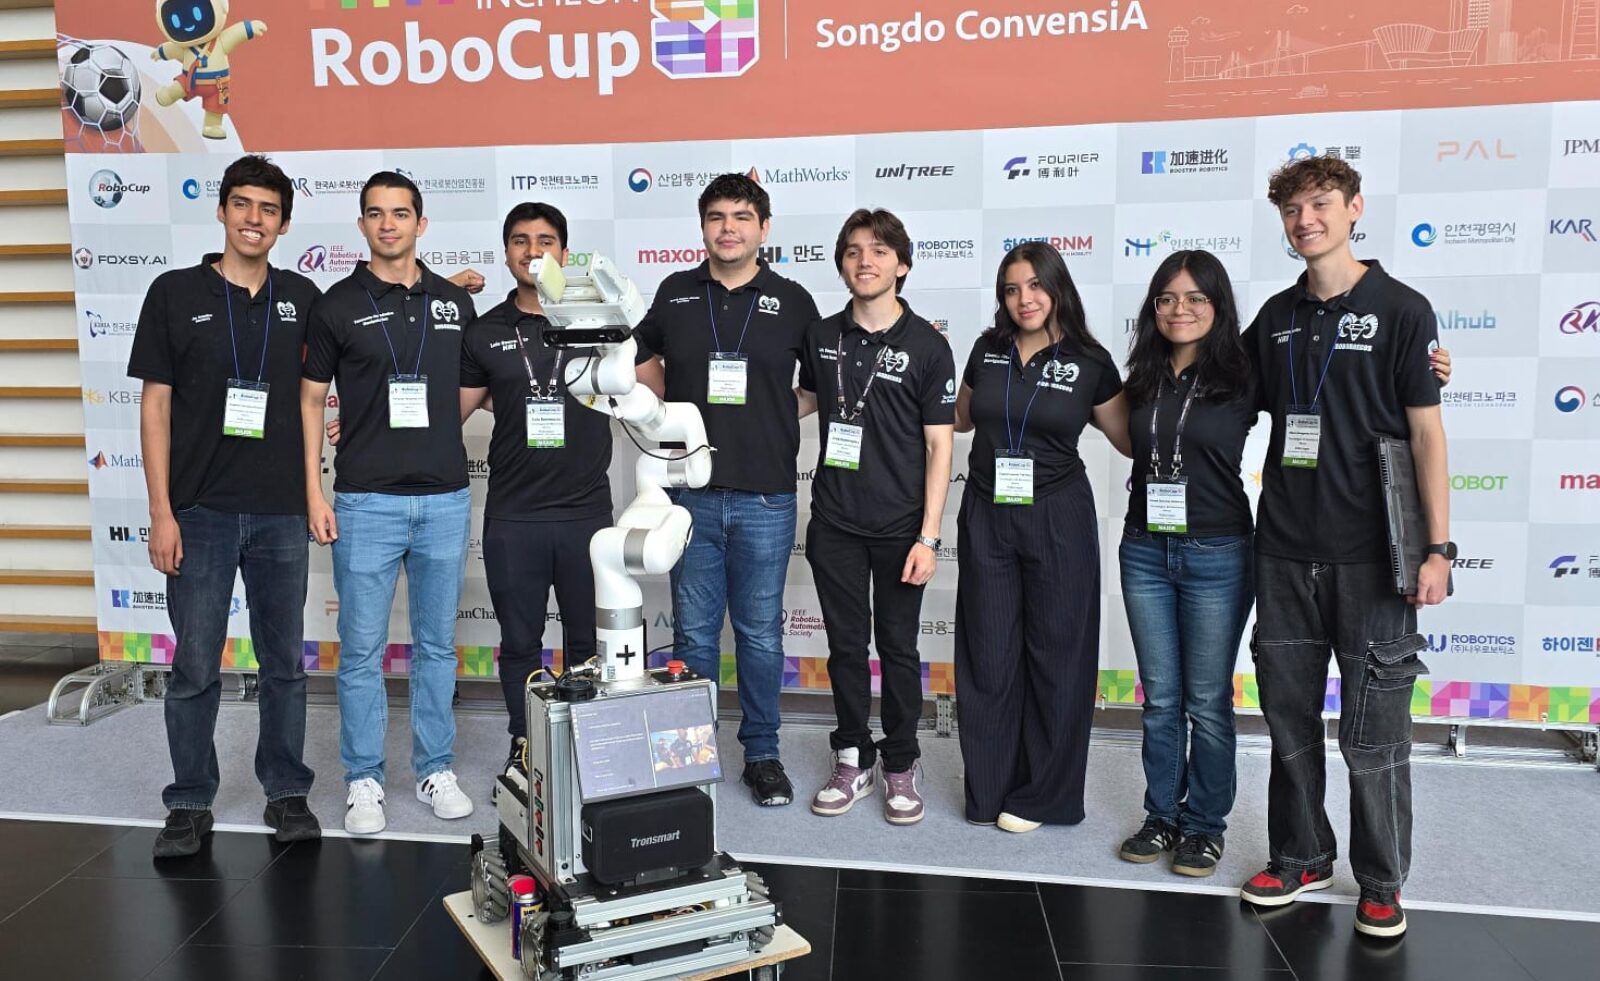
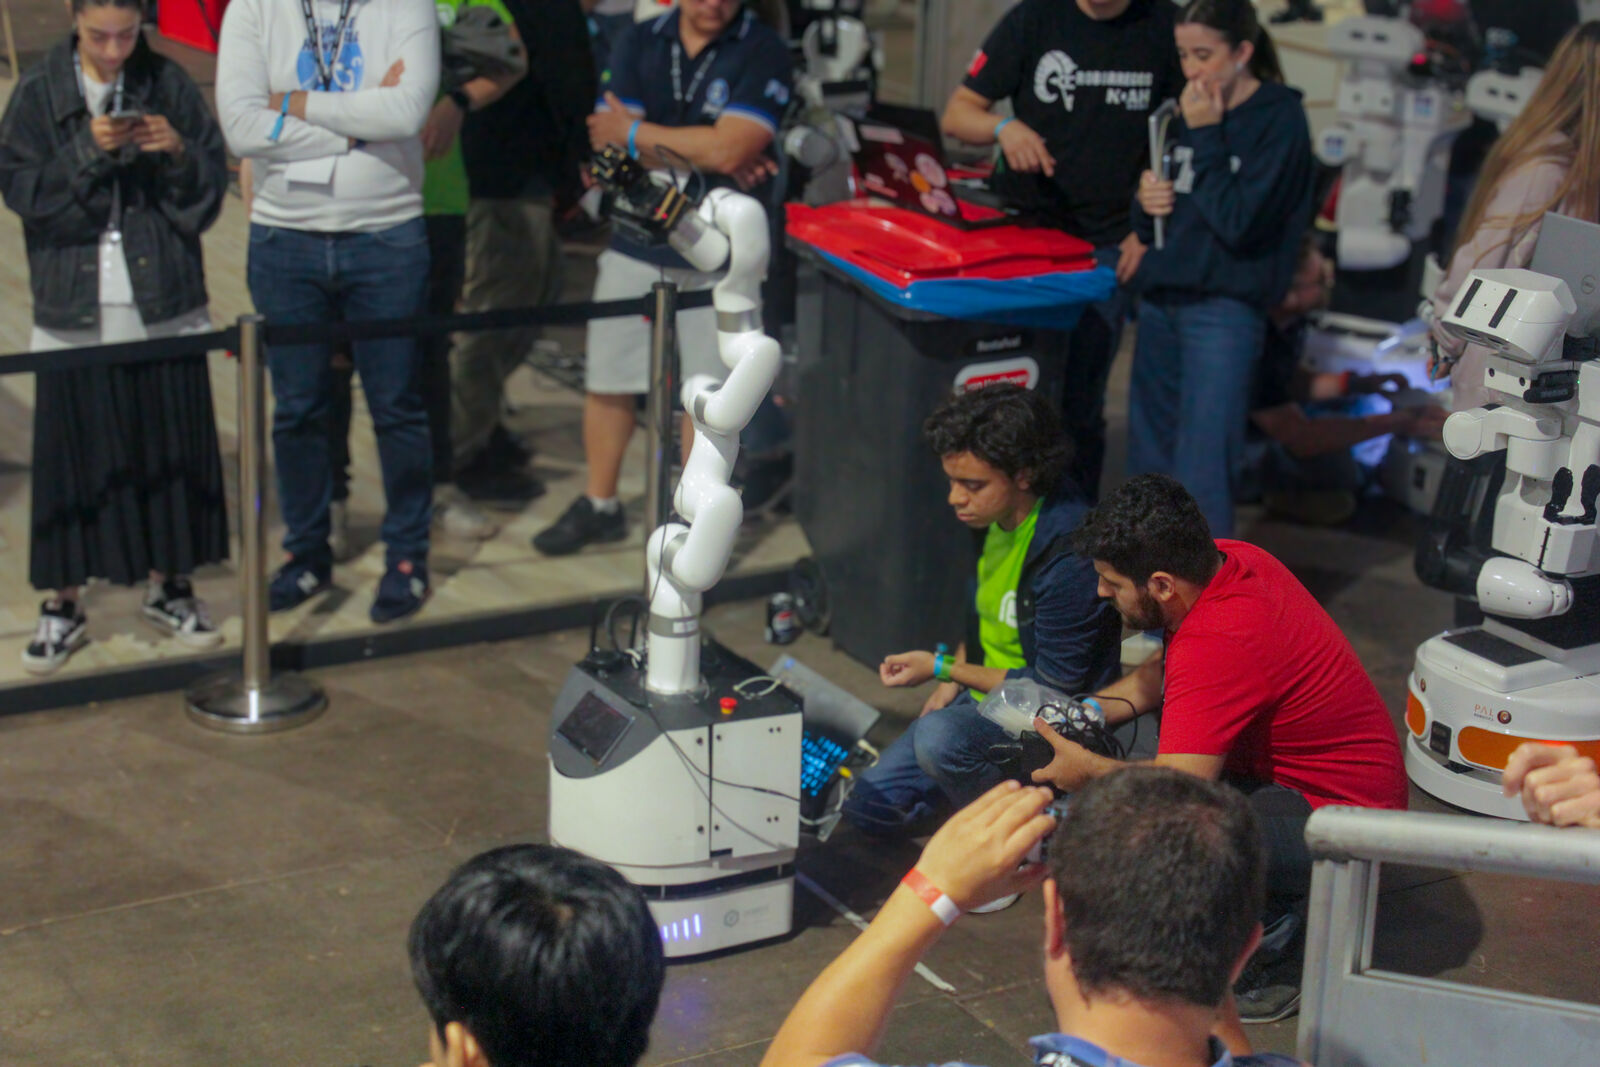
RoBorregos @Home team with FRIDA at RoboCup 2026, Incheon.
About the Competition
The RoboCup@Home league is the largest annual competition for autonomous service robots. It aims to develop service and assistive robot technology for future domestic applications. The competition evaluates robots' abilities in a realistic home environment through benchmark tests.
RoboCup@Home 2026 video
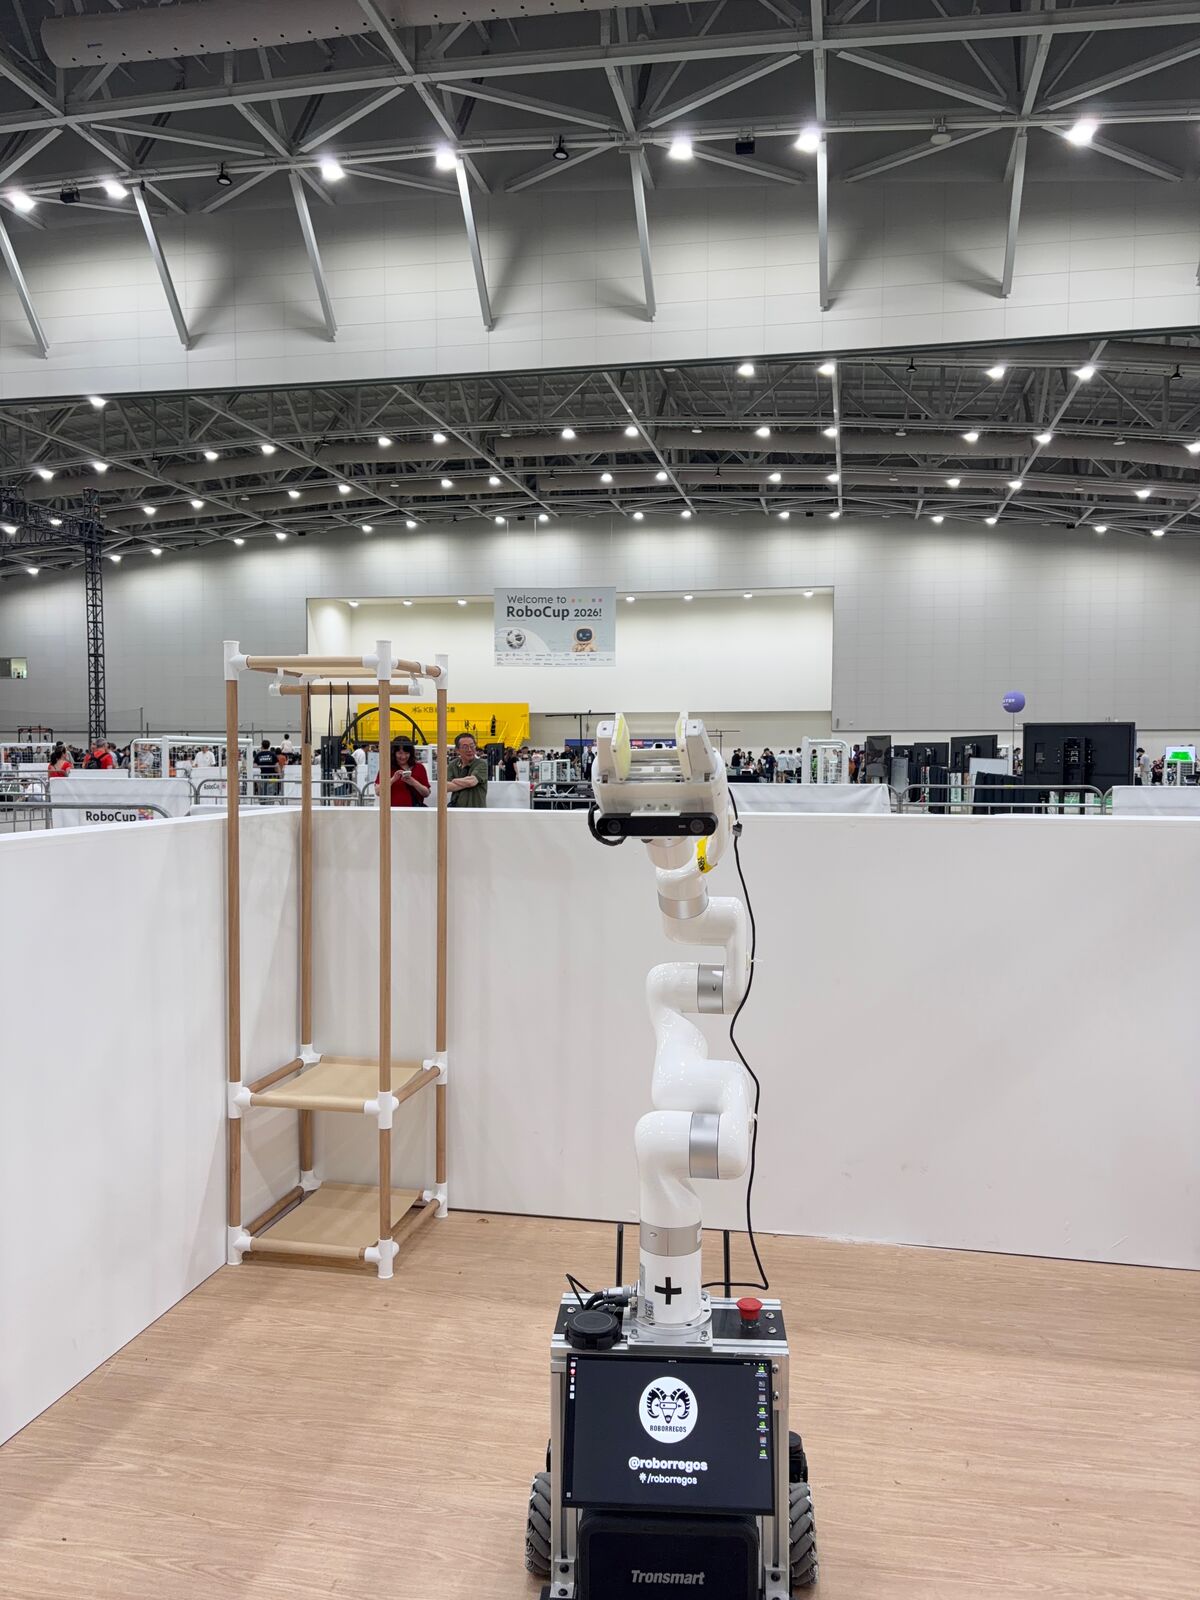
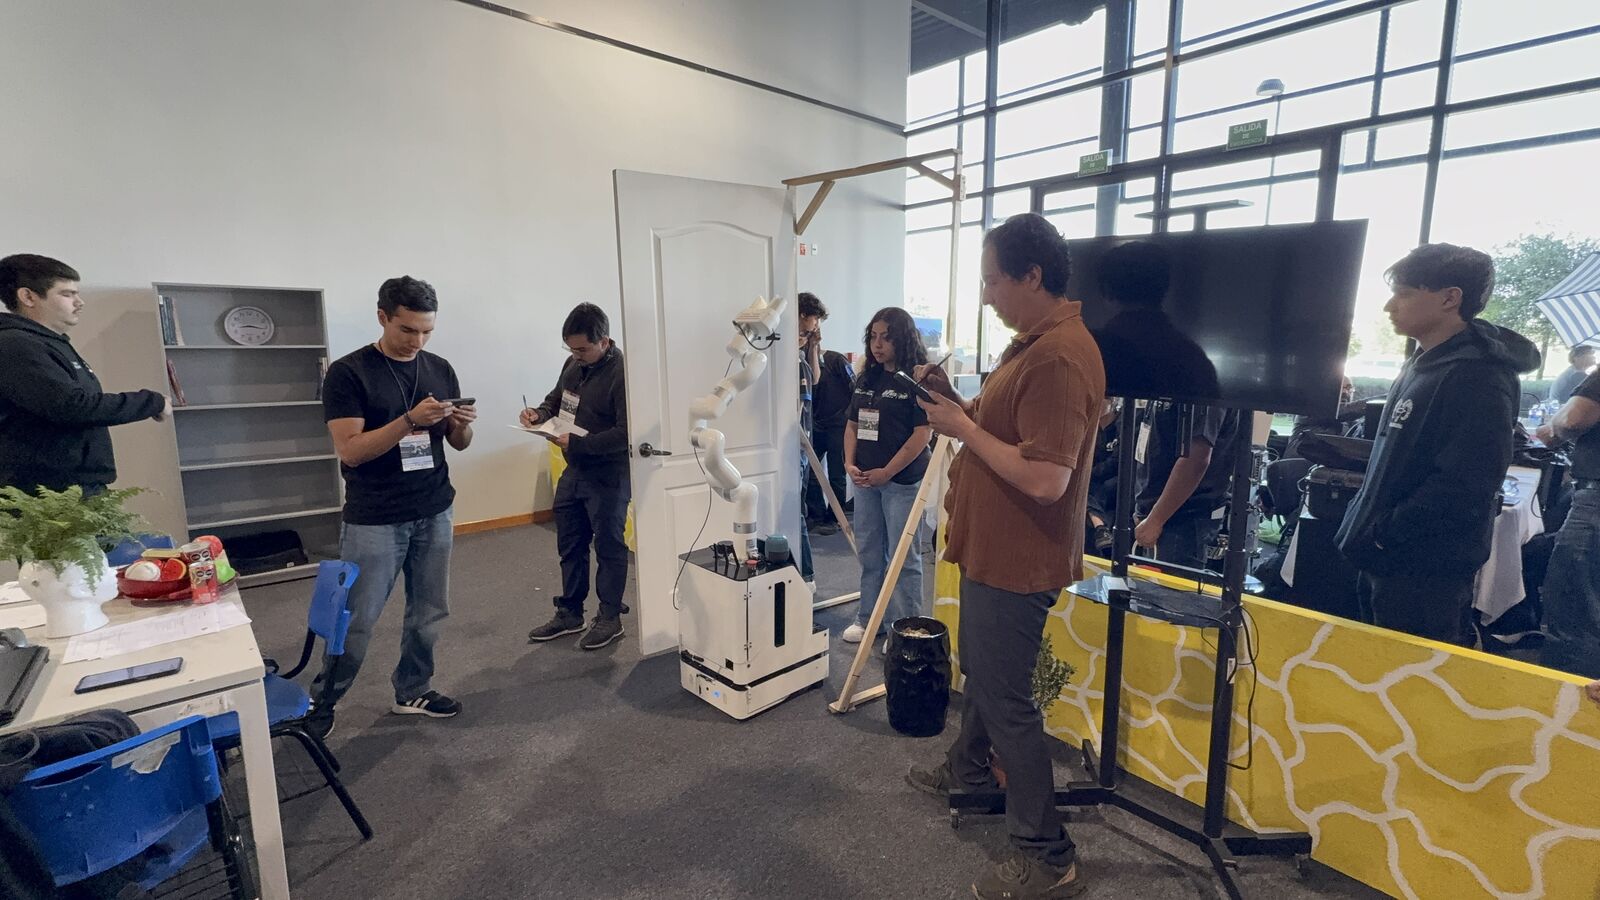
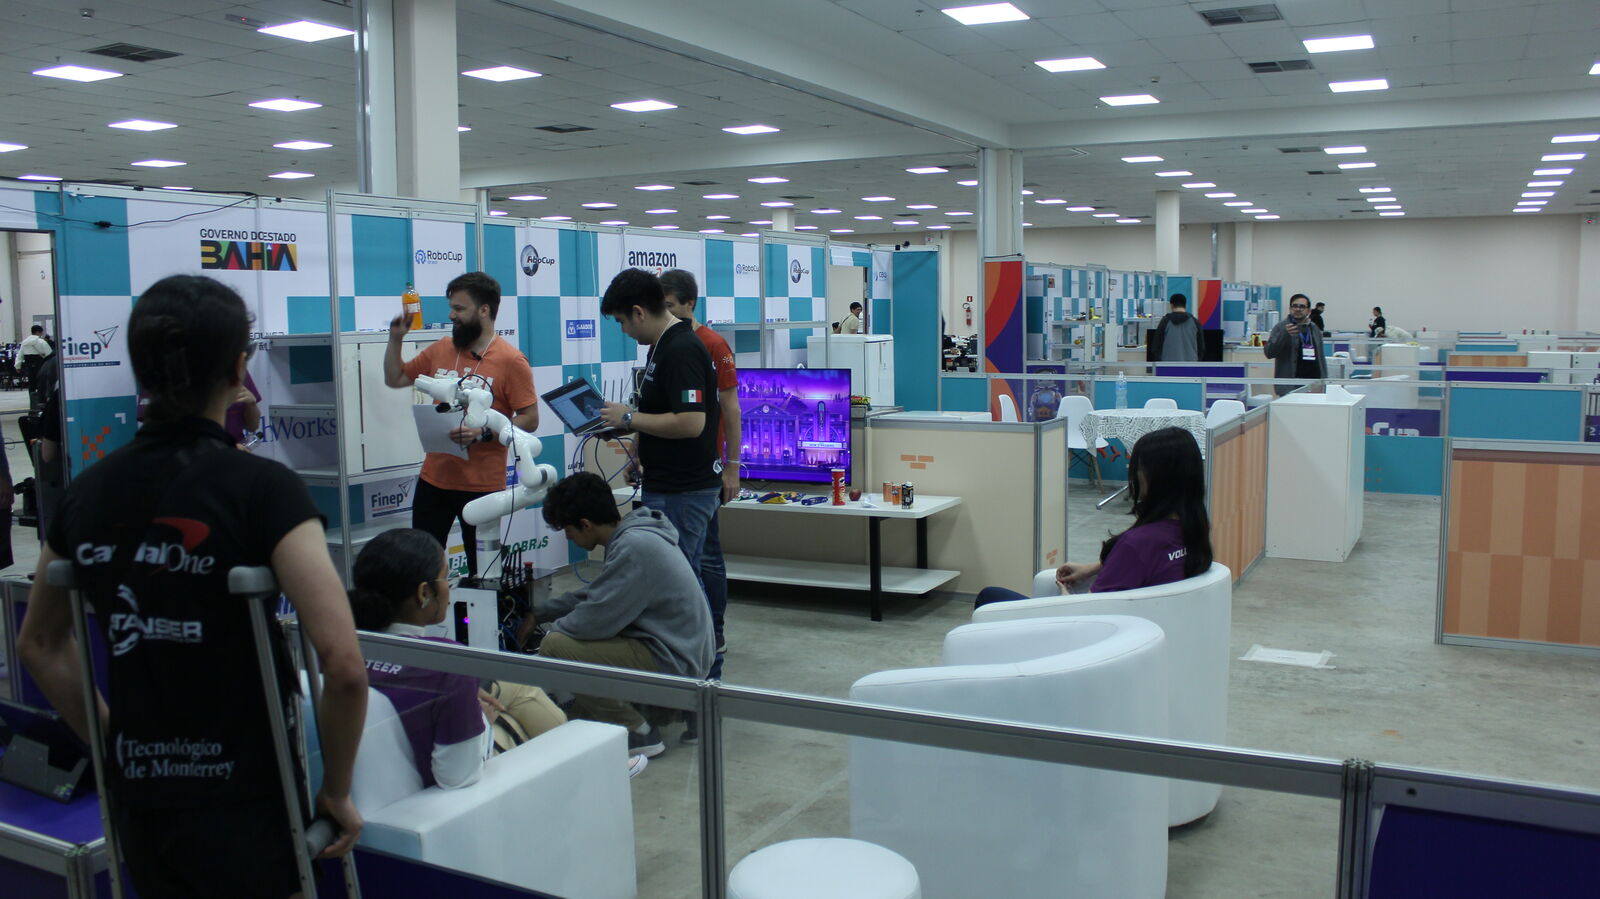
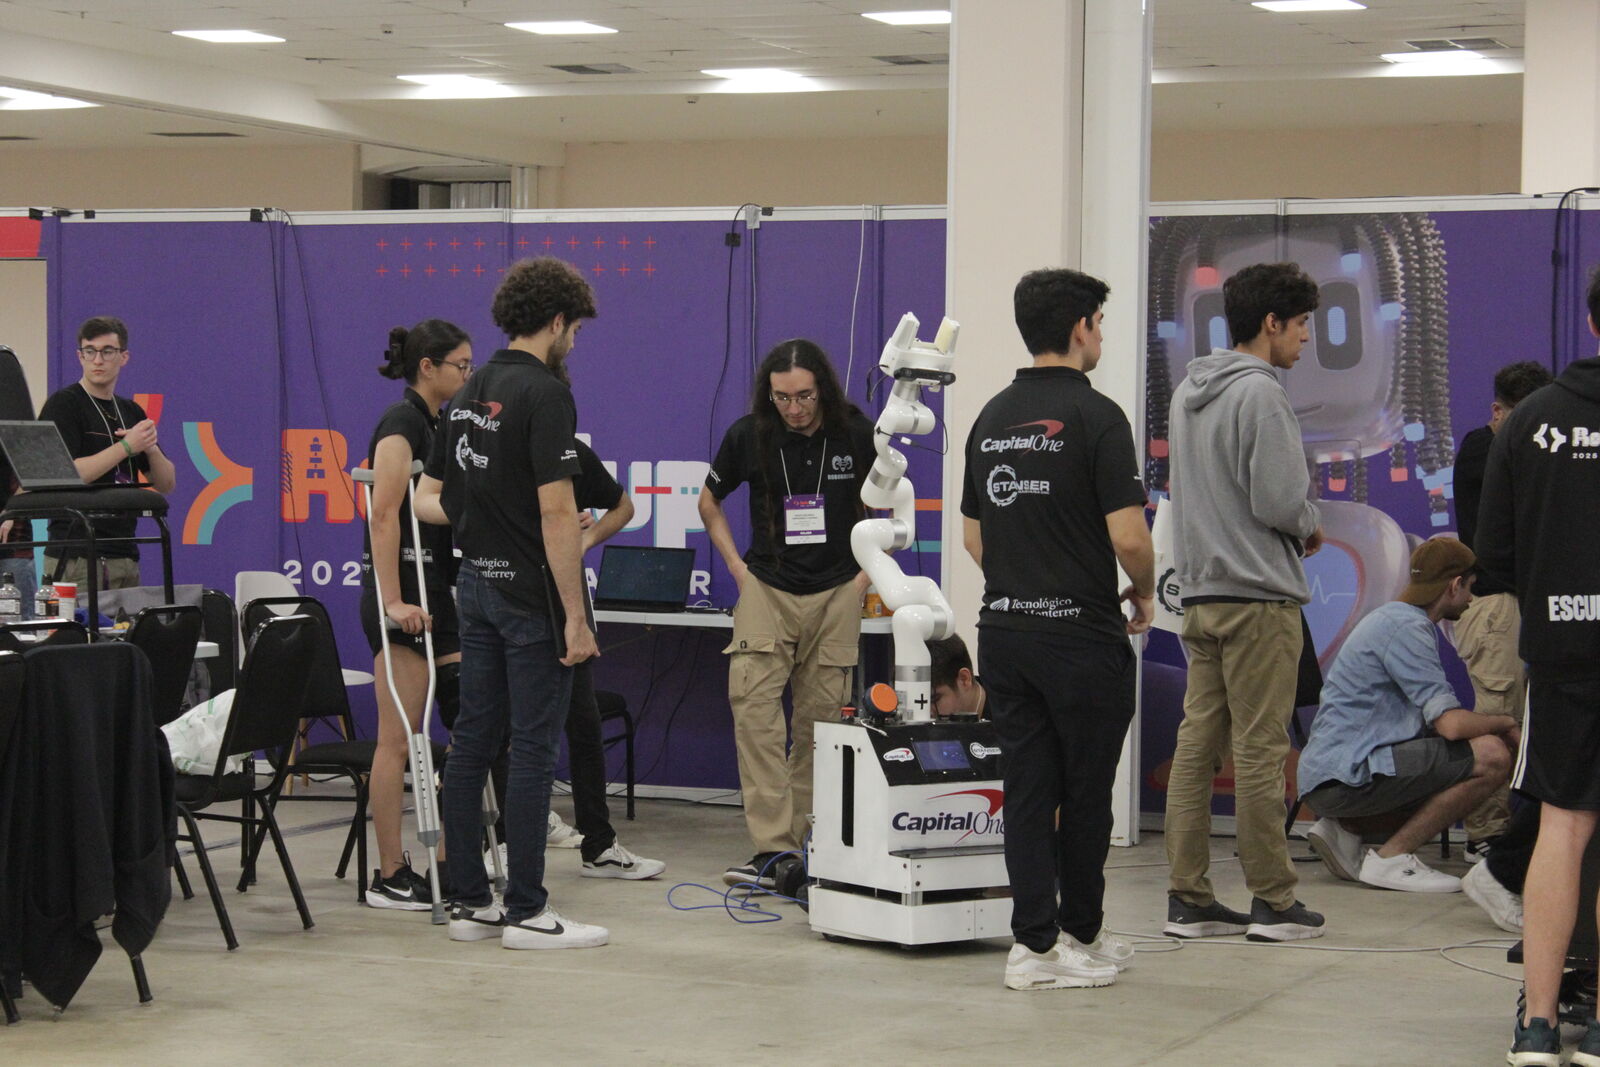
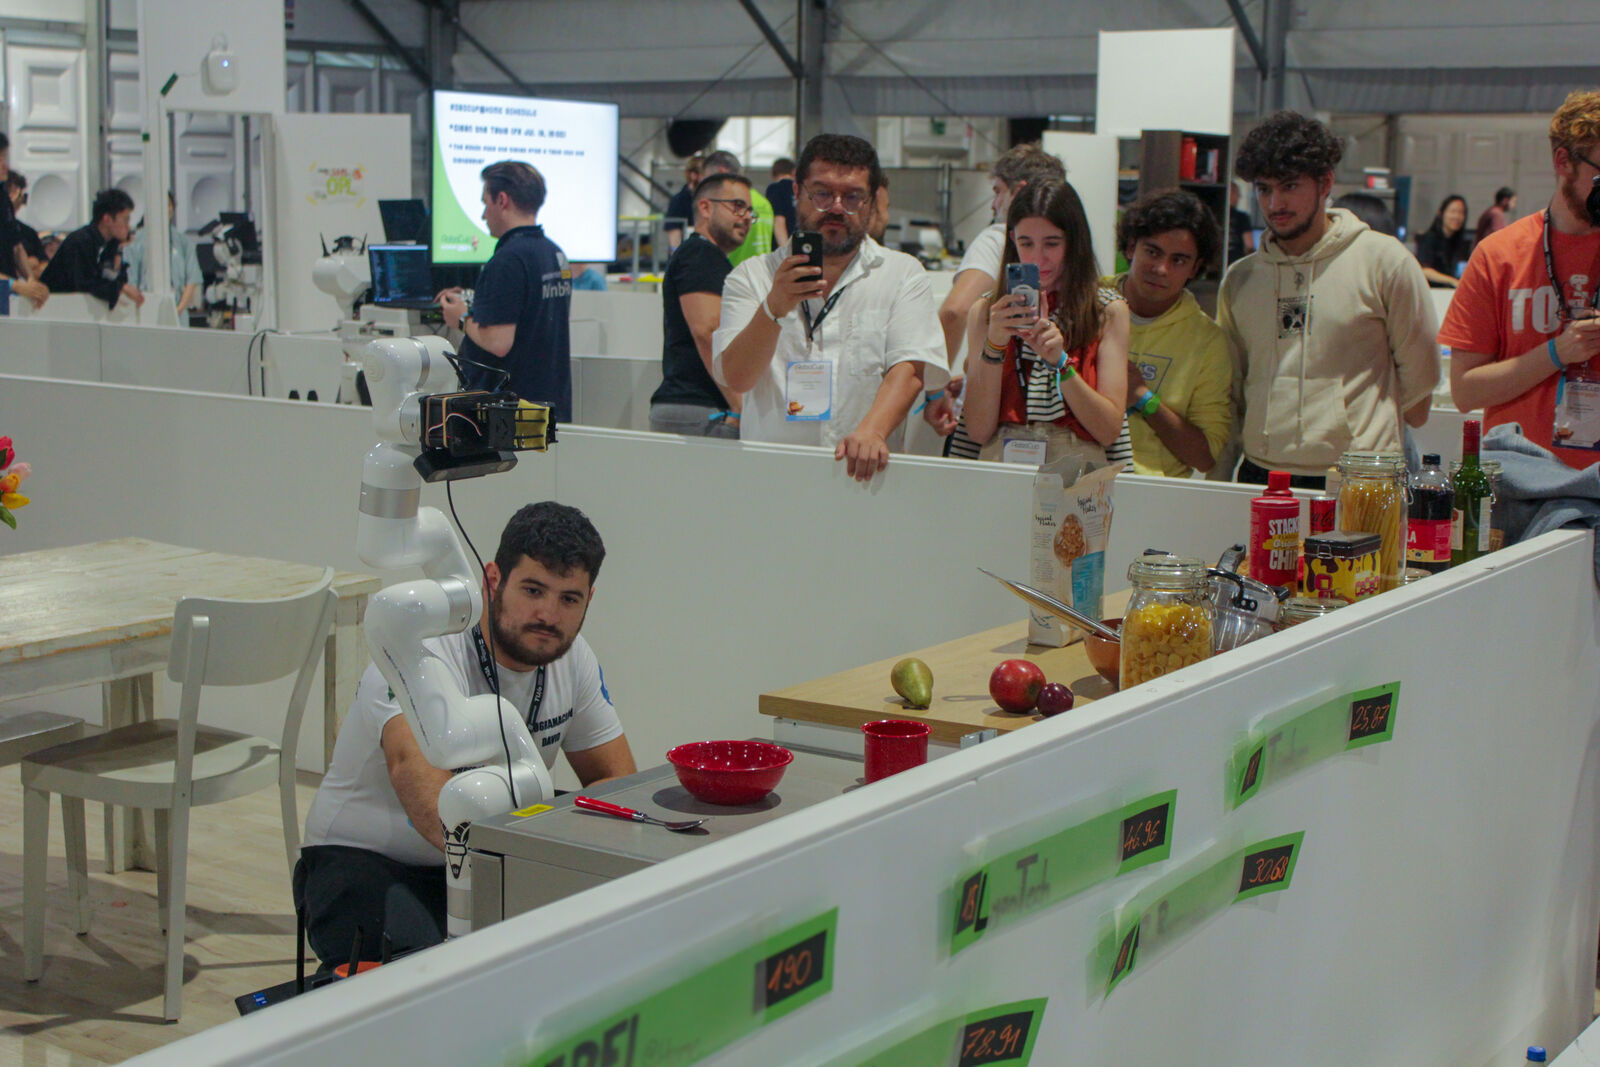
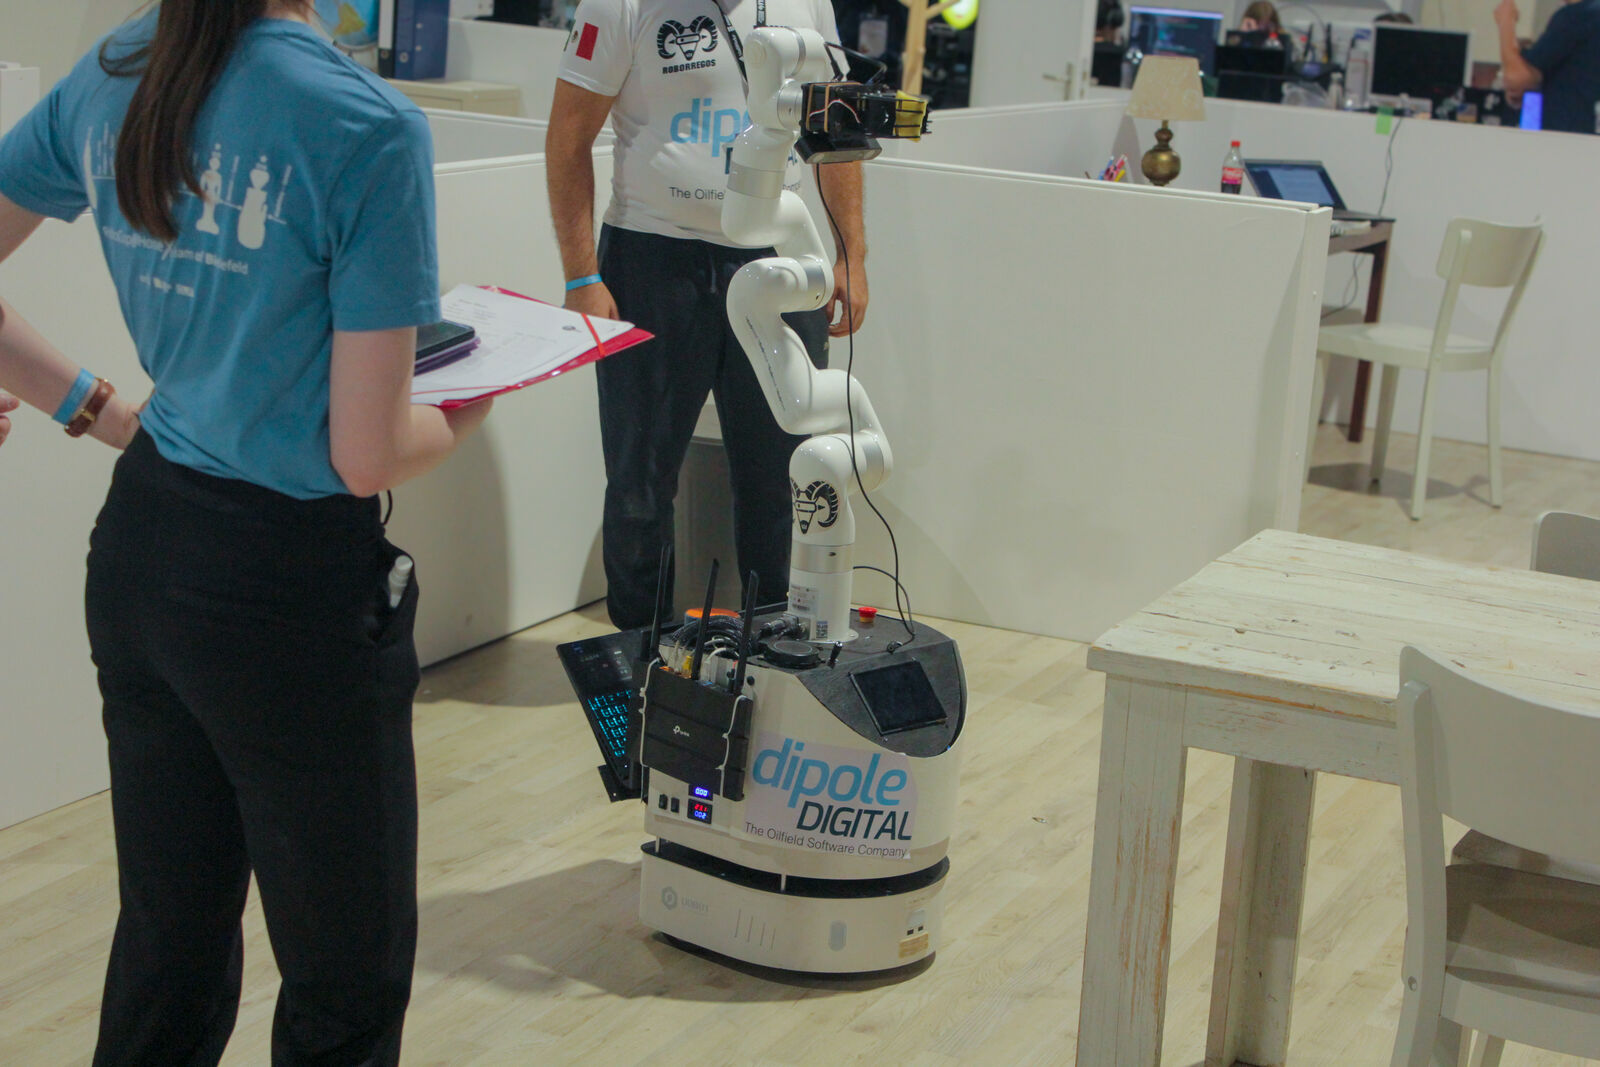


Explore Our Work
Achievements from 2026
Achievements from 2025
Achievements from 2024
Achievements from 2023
Prior achievements
Videos of our robot
Qualification Material
Material for the RoboCup@Home 2027 qualification:
- Team Description Paper: RoboCup@Home 2026 TDP. Previous TDPs are listed in Publications.
- Team video: RoboCup@Home 2026 video. More videos in Media.
- Robot: Hardware overview of FRIDA.
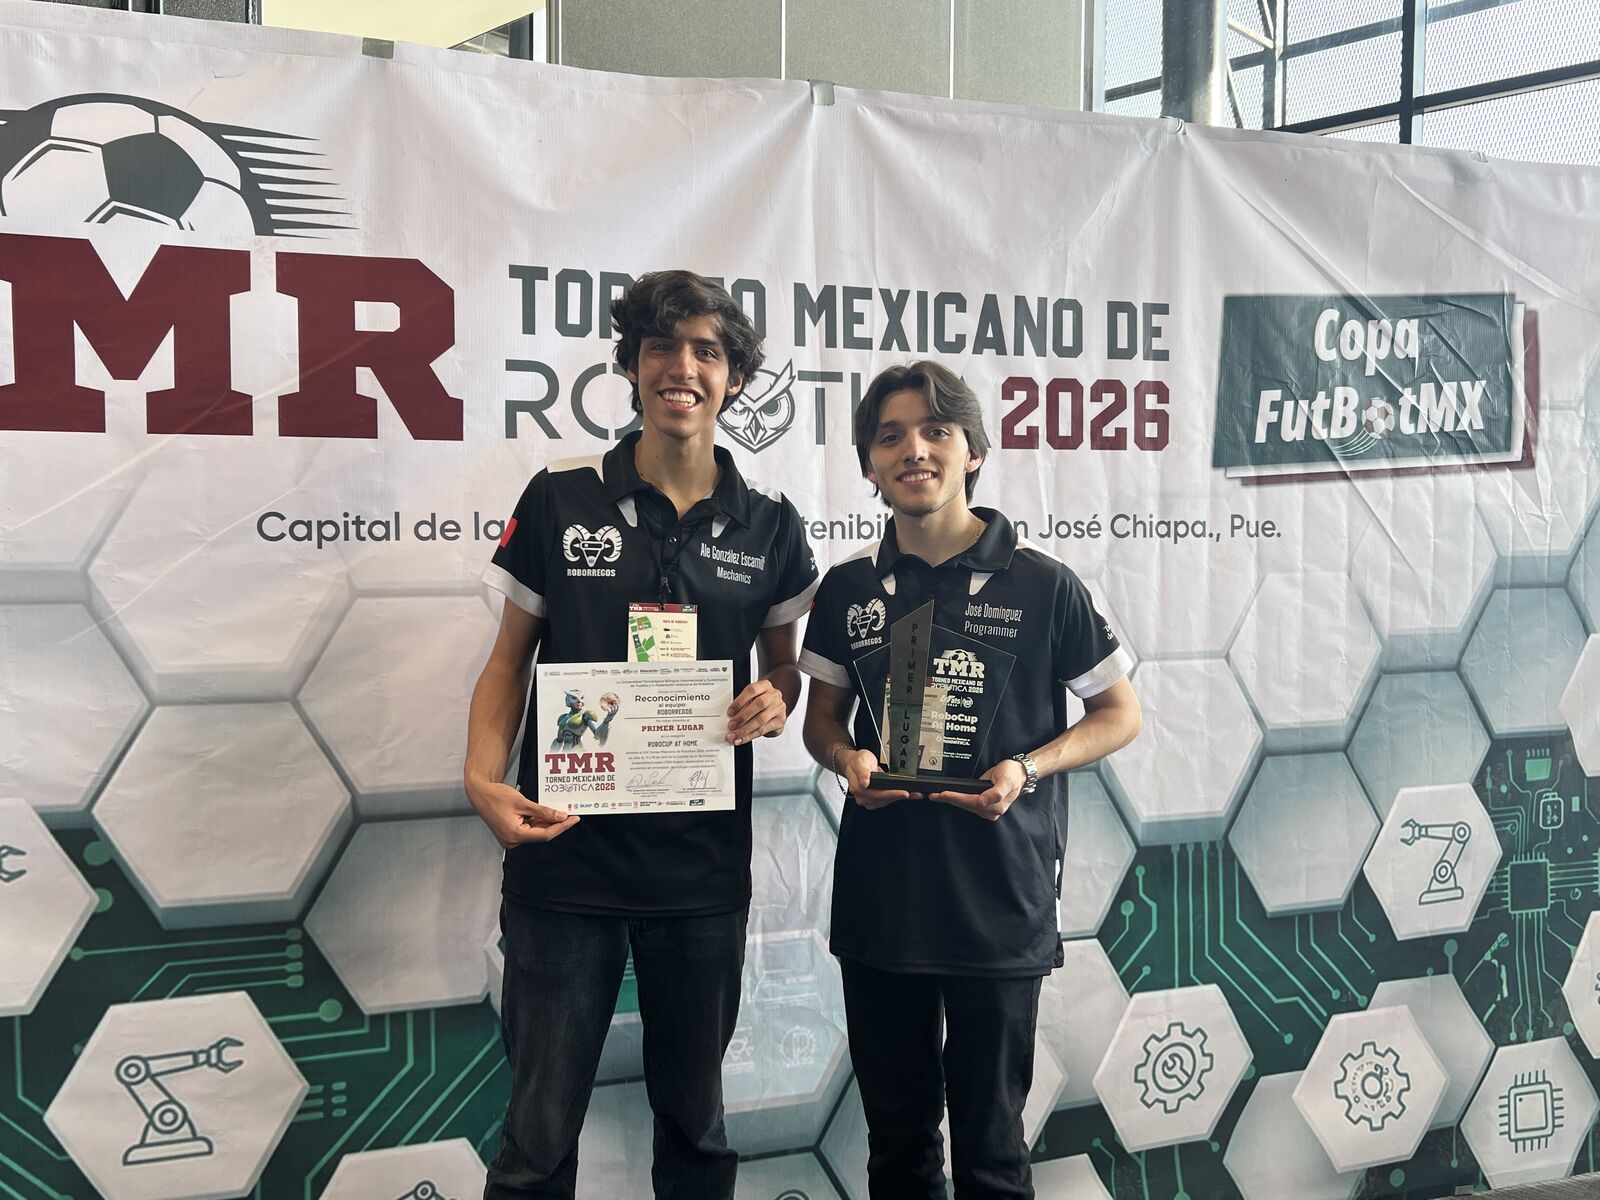
- Competition history: 1st place at TMR 2026, 9th place at RoboCup 2026 Incheon, 2nd place at TMR 2025, 6th place at RoboCup 2025 Salvador, 2nd place at TMR 2024 and 16th place at RoboCup 2024 Eindhoven. See all participations.
- Press: El Norte coverage.
- Team: Team leadership and members.
Open Source Software
All of FRIDA's software is open source and documented:
- RoBorregos/home2: main repository with the ROS 2 packages for HRI, vision, manipulation, navigation, simulation and the task managers.
- RoBorregos/home-custom-base: firmware (STM32, ODrive S1 over CAN, on-MCU EKF) and ROS 2 dashboard for the custom omnidirectional base.
- RoBorregos/home-pipelines: Jupyter notebook pipelines for the HRI command interpreter and the vision object detector.
Sections
This project is divided into several sections, each focusing on a specific aspect of the competition and the history of our team. The sections are as follows:
- Project structure: Provides an overview of the structure managed in the project. And how we are organized to achieve several tasks.
- Publications: Academic papers and research work by our team members.
- Areas: Describes the main software and hardware modules develop by the team to achive the functionalities in the robot.
- Team Members: Lists the team members and their roles in the project.
- Competition History: Previous RoboCup and Mexican Robotics Tournament participations.
- 2026
- 2025
- 2024
- 2023
- 2022
Contributing
Feel free to contribute to this documentation by submitting a pull request. If you have any questions or suggestions, please contact us.
Contact Us
If you have any questions, suggestions, or feedback, please feel free to reach out to us. We hope you find our documentation helpful and wish you success in exploring and utilizing our software modules for the RoboCup@Home competition.
We hope you find our documentation helpful, and we wish you success in exploring and utilizing our software modules for the RoboCup@Home competition.
If you want to see more of our projects, checkout our GitHub